HELIX: Failure Recovery and Experience Memory
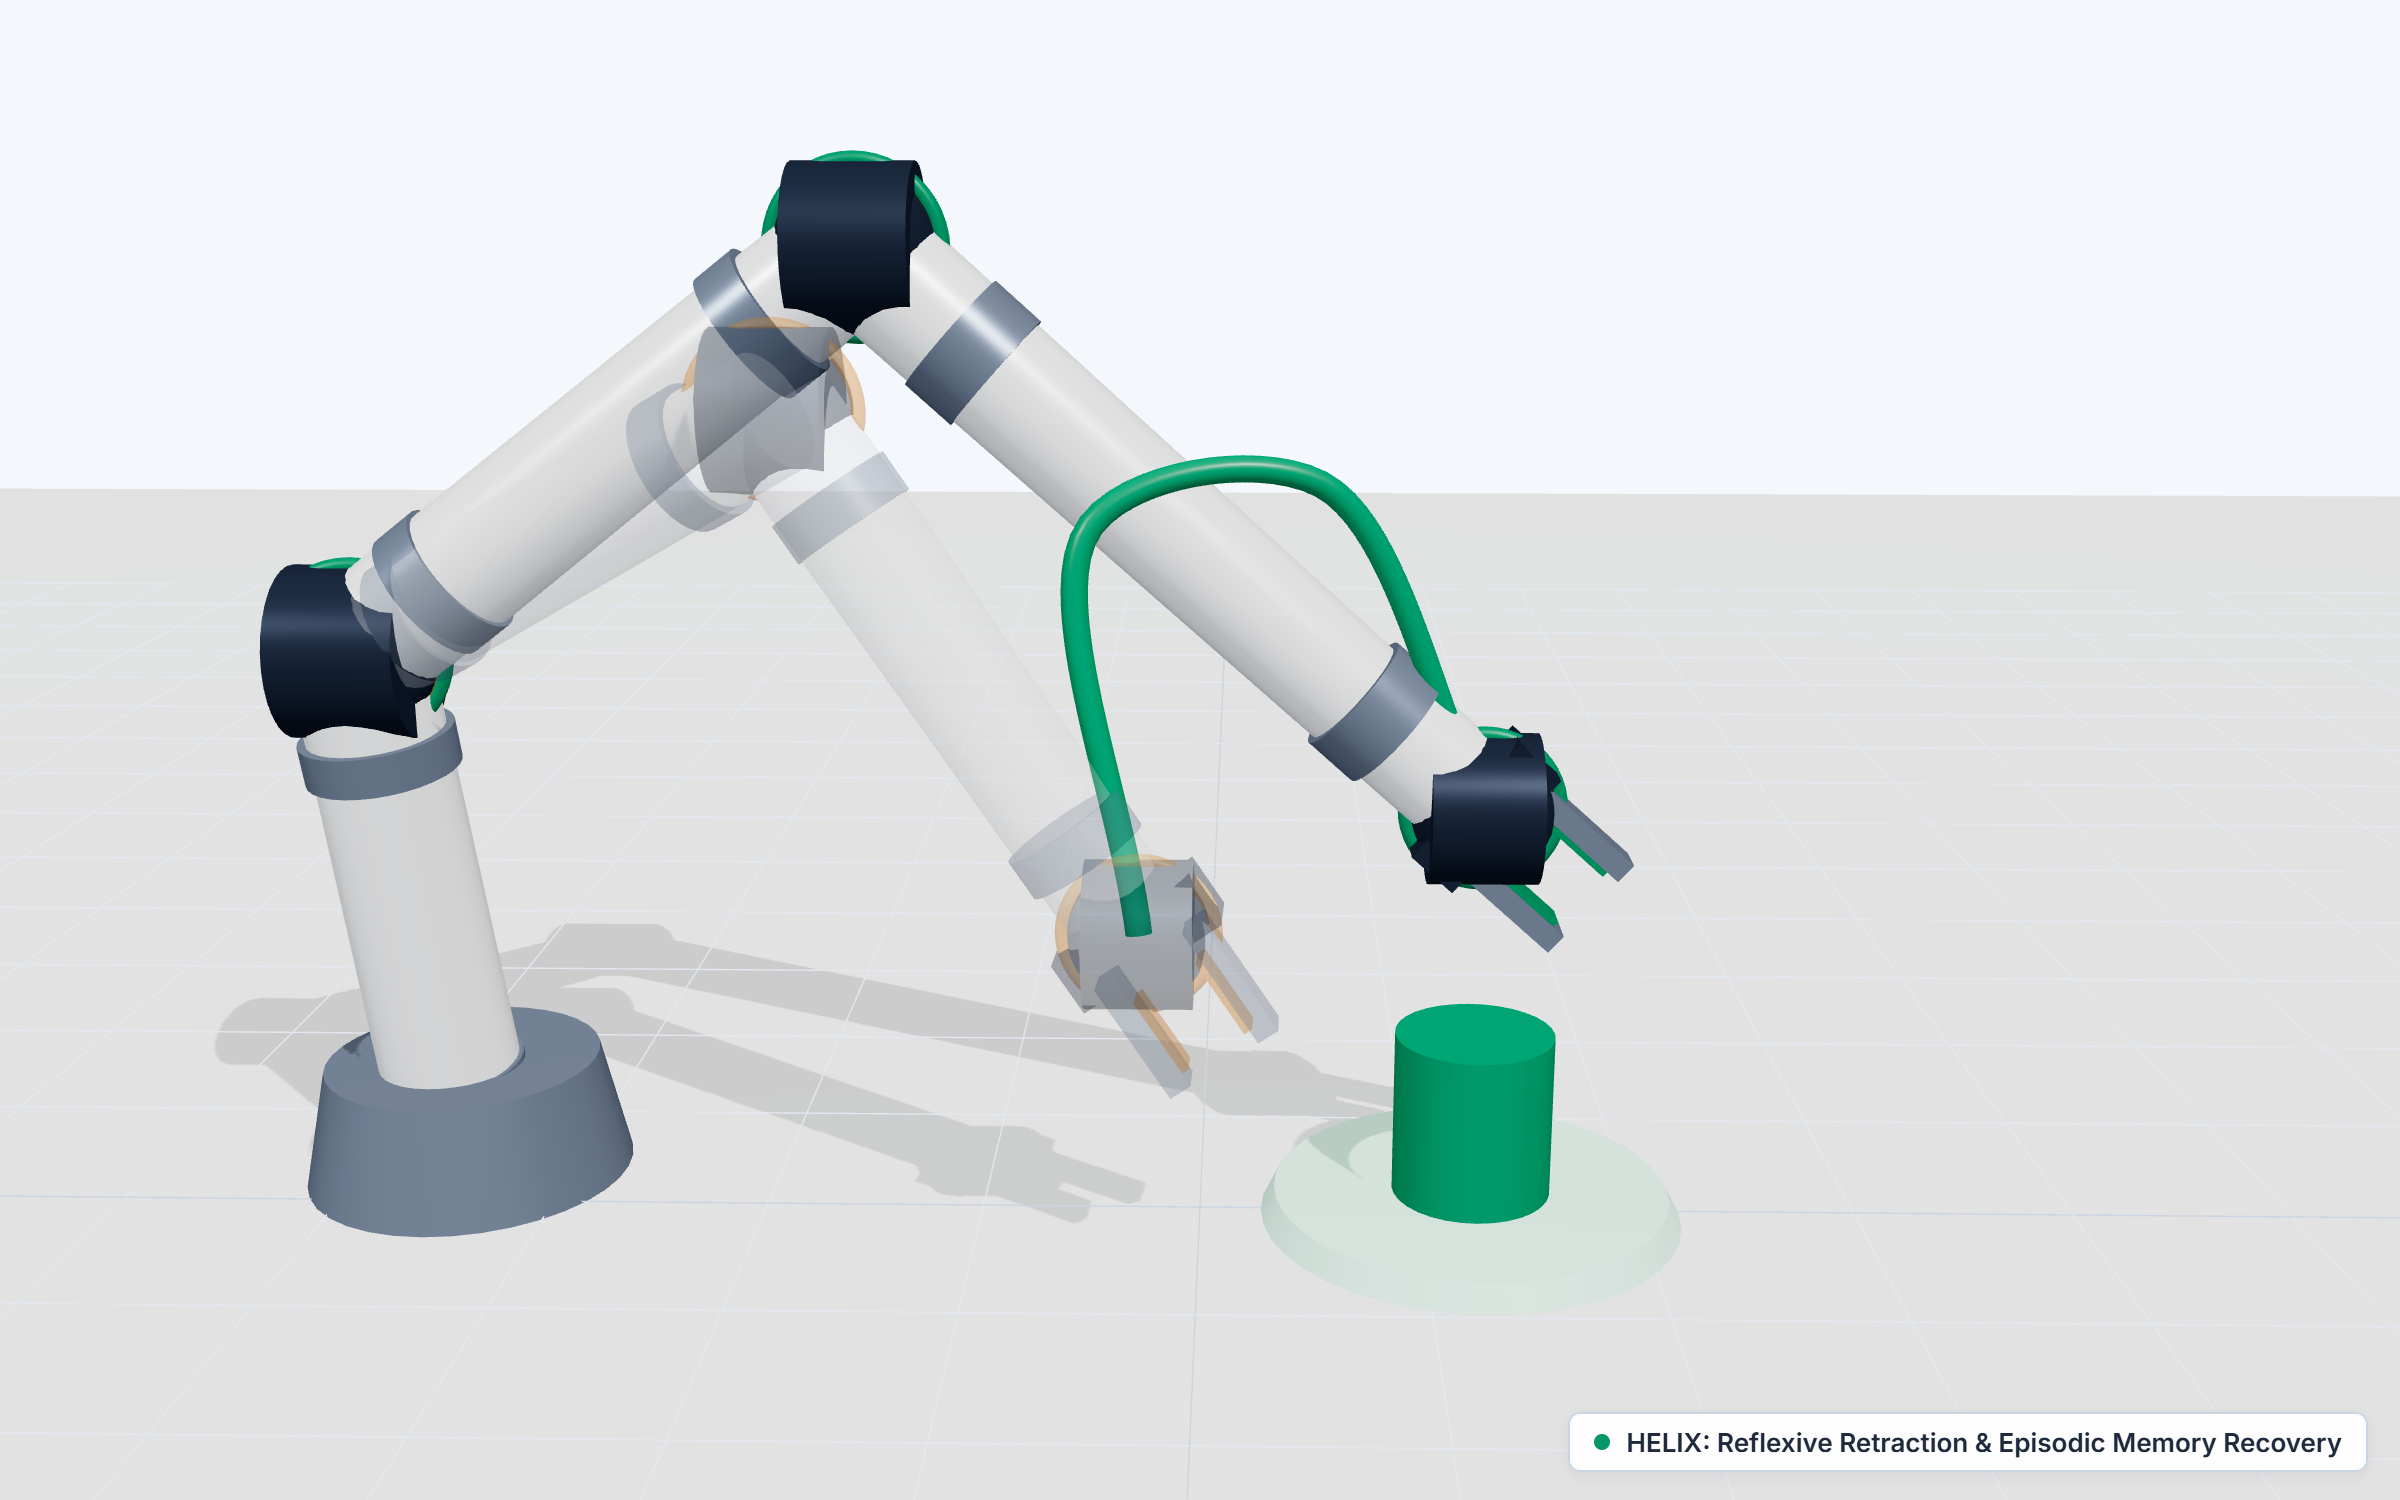
Ongoing Simulation Research · Failure Recovery & Experience Memory
Research Scope
Even well-trained manipulation policies encounter unexpected disturbances, slips, or suboptimal contact states during execution. HELIX investigates how a robotic agent can detect incipient execution failures early, halt unsafe motion, and synthesize corrective recovery actions without restarting from scratch.
Technical Architecture
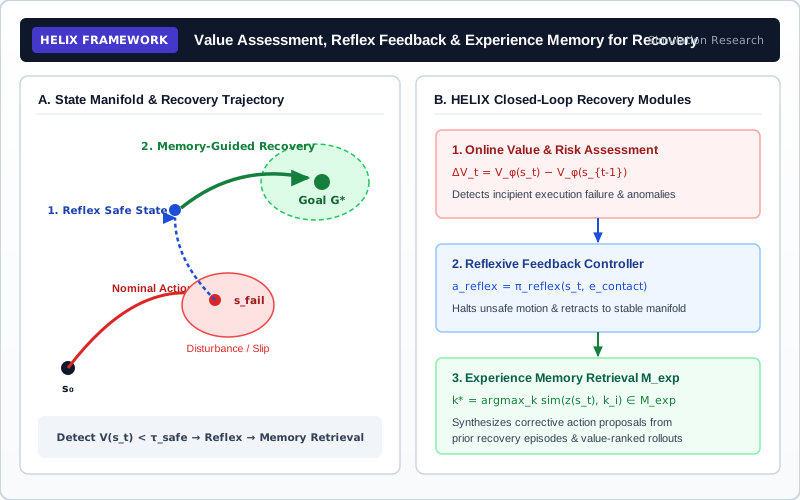
- Online Value Assessment: Monitoring state-value trajectories $V_\phi(\mathbf{s}_t)$ to detect anomalous transitions and assess recoverability before catastrophic task failure.
- Reflexive Feedback Control: Triggering fast, low-level reflex actions to retract the manipulator from unsafe contact manifolds back toward a recoverable state basin.
- Episodic Experience Memory ($\mathcal{M}_{\text{exp}}$): Retrieving prior successful recovery rollouts and value-ranked action proposals to guide closed-loop re-planning in simulation benchmarks.