Iterative Verify-and-Refine Vision-Language Agent for Reliable Dual-Arm Manipulation
Yuqi Cheng, Zhilun Hu, Cheng Jiang, Qingyu Peng, Weiming Shen.
Manuscript Under Review · Second Author.
Abstract & Method Overview
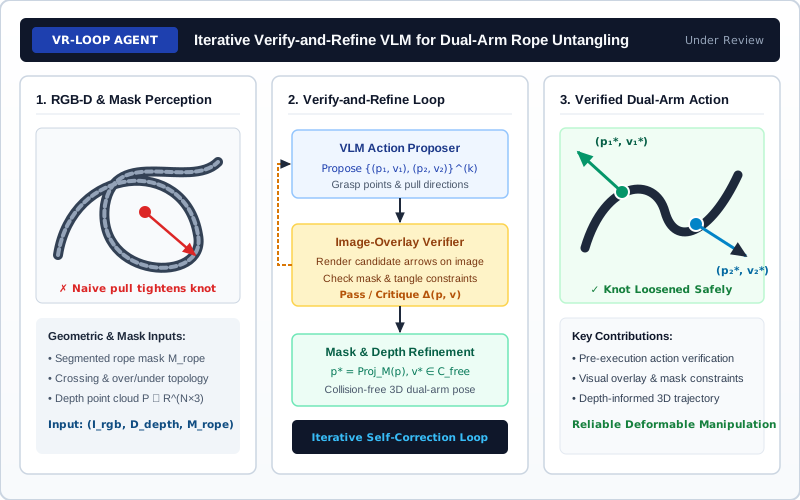
In deformable linear object manipulation (such as dual-arm rope untangling), open-loop action proposals from vision-language models can place grasps off the rope geometry or pull along directions that tighten the knot. VR-Loop introduces an iterative Verify-and-Refine paradigm: candidate grasp points and pulling vectors are visually rendered onto image overlays, critiqued against crossing topology and mask constraints before physical execution, and lifted via RGB-D depth geometry into collision-free dual-arm trajectories.
BibTeX
@unpublished{cheng2026vrloop,
  title  = {Iterative Verify-and-Refine Vision-Language Agent for Reliable Dual-Arm Manipulation},
  author = {Cheng, Yuqi and Hu, Zhilun and Jiang, Cheng and Peng, Qingyu and Shen, Weiming},
  year   = {2026},
  note   = {Manuscript under review}
}